
Turning a simulation idea into a working application has traditionally required a painstaking sequence of engineering tasks: assembling disjointed assets, meticulously connecting complex physics models with advanced rendering pipelines, and running countless validation checks to ensure virtual scenes behave as intended. Now, developers are fundamentally transforming this workflow by combining frontier artificial intelligence models with NVIDIA Omniverse libraries. Across various technical domains, engineers are leveraging natural-language instructions to direct AI agents in building sophisticated applications capable of exploring intricate scenarios, investigating mechanical failures, and refining real-world product designs.
Rather than writing extensive boilerplate code from scratch, developers can direct AI agents through plain-language prompts, review the generated outputs in real time, and guide iterative changes. NVIDIA Omniverse libraries supply the foundational architecture behind these workflows, delivering GPU-accelerated physics, high-fidelity rendering, and advanced sensor simulation capabilities. By bridging the gap between high-level conceptual ideas and executable code, this approach is accelerating the pace at which complex digital environments and robotics testing grounds are brought to life.
Build a Humanoid Simulator for a Warehouse Environment
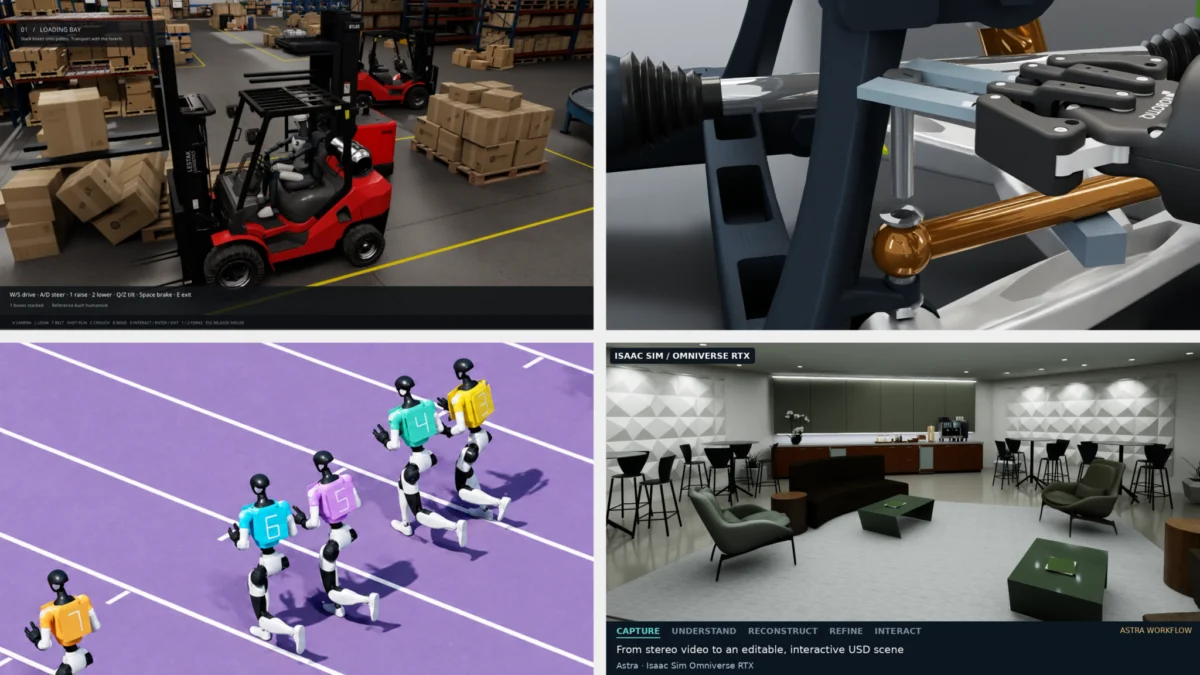
Before organizations can successfully automate complex warehouse operations, developers require interactive simulation environments to explore how robots behave during specific tasks and to evaluate how physical work gets carried out in a structured space. Frank DeLise, an Omniverse product manager at NVIDIA, recently demonstrated how frontier AI models like GPT-6 Astra could be utilized to turn a pre-existing SimReady warehouse environment and a humanoid robot into an interactive simulator featuring both first- and third-person viewing modes.
In this project, DeLise directed the AI agent to connect various NVIDIA Omniverse libraries, including ovphysx for physics calculations, ovstage for dynamic scene updates, ovrtx for advanced rendering, and ovui for user interface design. By combining Astra with the foundational SimReady asset library, the system successfully established the physical scene within the simulation framework. Astra then automatically generated the necessary animation and application code to bind these disparate capabilities together, resulting in a gamified, physics-based control system for a humanoid robot operating within a virtual industrial setting.
Connect an Autonomous-Driving Testing Workflow
In the realm of autonomous vehicle development, introducing even minor changes to a virtual scene, a sensor configuration, or a driving model can trigger significant ripple effects across the entire simulation. Doyub Kim, a manager on the simulation technology team at NVIDIA, sought to address this complexity by asking Astra to construct a reusable simulation environment known as Zero to Alpamayo, which was modeled after a bustling stretch of San Francisco’s Market Street.
Kim directed the AI agent to map out the overarching workflow step by step, subsequently connecting asset creation, simulated traffic patterns, Omniverse RTX sensor simulation, and Alpamayo driving models in sequential stages while verifying each integration along the way. The resulting prototype served as a robust testing ground, allowing engineering teams to compare different driving models and trace precisely how modifications to the surrounding scene or onboard sensors impacted downstream driving behavior. In a complementary experiment utilizing Cosmos3-Nano, the team varied weather and lighting conditions within recorded simulation videos, enabling Kim to evaluate how the driving model responded to identical driving scenarios under drastically different environmental conditions.
Use Sensor Differences to Create and Improve Digital Twins
To effectively test robots and autonomous vehicles in virtual spaces, developers must verify how closely simulated sensors match their real-world counterparts. Ashley Reid, who works on RTX sensor validation at NVIDIA, directed Astra and Claude Fable 5 agents to rigorously compare ovrtx camera and raw LiDAR outputs against actual recorded data. Through this collaborative effort, the AI agents successfully created two complete digital twins from scratch while simultaneously improving two pre-existing ones.
Over the course of roughly three days, Reid guided an iterative workflow where the autonomous agents measured discrepancies, created or modified OpenUSD scenes, and verified the results against established metrics. The adjustments targeted missing objects, geometric inaccuracies, and material properties, with final acceptance relying strictly on quantitative camera and LiDAR metrics. This methodology provides developers with a structured way to utilize real-world sensor discrepancies as a guiding mechanism for scene creation and digital twin refinement.
Robo Olympics: Test Robot Skills With Simulation
Teaching advanced robots new physical movements requires rigorous validation to ensure those actions remain viable under strict physical constraints. Tae Kim, who leads NVIDIA Omniverse engineering and product, utilized reference sports videos and natural-language instructions to guide Astra in building Robo Olympics—an experimental project designed to test simulated Unitree G1 humanoid robots performing complex athletic maneuvers.
Operating under Kim’s direct guidance, Astra constructed custom controllers and continuously refined them through iterative physics trials. The Newton Physics Engine simulated realistic physical behaviors, the open-source NVIDIA Warp framework accelerated the underlying numerical calculations, and ovrtx handled the rendering of scenes and virtual-camera imagery. In one notable experiment, the humanoid robot successfully cleared a single hurdle in 64 out of 100 simulation trials, providing Kim with valuable performance feedback that could be used to fine-tune the robot’s timing and motor controls.
Test Robotic Disassembly With Computer-Aided Design and Simulation
Before a robot can be deployed to safely disassemble a manufactured product, developers need absolute certainty that its robotic tools can successfully reach, grasp, and remove targeted components. Jens Jebens, a senior product manager for OpenUSD at NVIDIA, directed Astra to model a car suspension system using PTC Onshape and configure it directly within NVIDIA Isaac Sim.
Leveraging Astra, Jebens explored computer-aided design and tooling revisions informed entirely by simulation data. The AI agent measured the available physical clearances within the assembly and designed a custom wrench that the robot could successfully manipulate to reach the suspension’s recessed bolts. Jebens ultimately reported the successful removal of a suspension component within the simulation environment. This workflow effectively connects upstream design and tooling choices to downstream disassembly outcomes, establishing a reliable starting point for subsequent robot policy training.
Bring the International Space Station Into the Browser
Translating complex 3D models into a fully functioning application demands the seamless integration of raw assets, live data feeds, and an intuitive user interface. Nic Johns, an engineering director at NVIDIA, prompted Astra to assemble raw NASA assets into a comprehensive OpenUSD model of the International Space Station equipped with live telemetry data. Johns successfully built the application using a single prompt, then issued a follow-up instruction to adjust the scene so that the daylight side of Earth was clearly visible in the background.
The underlying workflow relied on Blender for initial asset preparation alongside a suite of Omniverse libraries dedicated to rendering via ovrtx, scene runtime management via ovstage, and real-time streaming via ovstream. By uniting 3D models and operational data directly within a standard web browser, the application demonstrates how natural-language prompting can guide the rapid creation of complex visualization tools.
Turn Captured Rooms Into Testing Environments
Digitally reconstructed rooms require fully editable objects and accurate physical behaviors before developers can reliably test human-robot interactions. Chirag Majithia, a member of the Isaac engineering applications team at NVIDIA, directed Astra to transform raw stereo camera captures into an editable OpenUSD studio environment.
The reconstruction pipeline combined PyCuSFM, FoundationStereo, and nvblox technologies, with human review guiding the subsequent object selection and placement stages. Astra then assembled both generated and Blender-authored assets, employing USD Content Agents to configure how individual objects should move and interact within the simulation. Subsequent Isaac Sim tests guided necessary collision and contact revisions for articulating doors and drawers. By connecting captured physical geometry directly to rigorous interaction testing, the approach makes it significantly easier for engineering teams to spot spatial gaps and evaluate realistic object behaviors in virtual workspaces.


No comments yet. Be the first to join the conversation!